
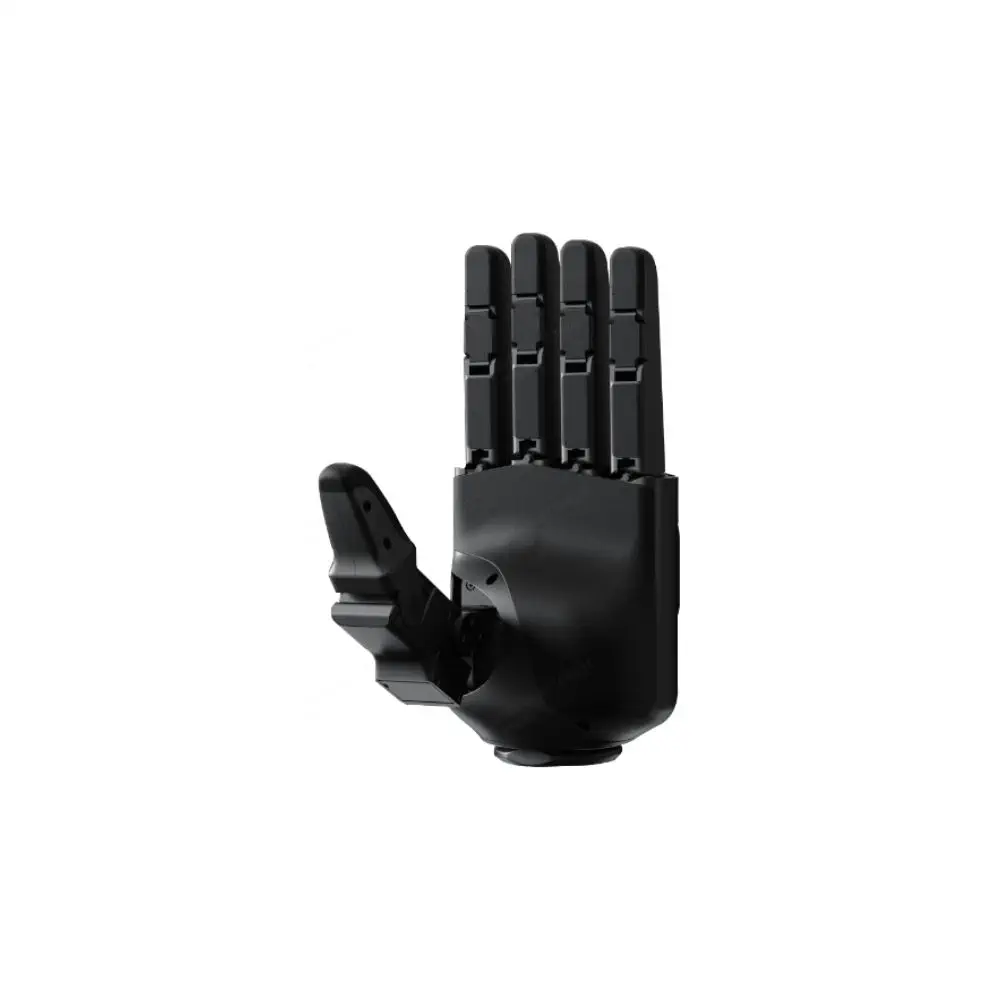
H2 Dex5-1 FiveFinger Dexterity Hand for Advanced Robotic Manipulation
H2 Dex5-1 FiveFinger Dexterity Hand is a high-performance robotic hand designed specifically for the Unitree H2 humanoid robot. Featuring 16 active degrees of freedom, it delivers precise finger articulation for object manipulation, robotic research, AI development, and advanced grasping applications.
The hand utilizes 12 self-developed micro-force-controlled composite transmission joints and 4 precision gear transmission joints, enabling smooth finger motion and accurate proprioceptive control without relying on tactile sensing. Its optimized joint design allows stable grasping while maintaining natural finger movement across a wide range of motions.
With 10N fingertip force, ±1 mm repeatability, and a minimum grasping diameter of 10 mm, the hand is suitable for precision manipulation tasks. Real-time feedback including joint position, speed, torque, temperature, voltage, current, and IMU data supports advanced robot control and secondary development.
This product is supplied as a single dexterous hand. A complete Unitree H2 robot typically requires two hands. It is intended as a replacement or repair component and is not available for individual standalone installation.
Key Features
16 Degrees of Freedom
Provides independent thumb and finger movement for flexible and precise robotic manipulation.
Micro-Force-Controlled Transmission
Features self-developed composite transmission joints for smooth motion and accurate proprioceptive control.
High Precision Grasping
Supports a minimum grasping diameter of 10 mm, 10N fingertip force, and ±1 mm repeatability.
Real-Time Motion Feedback
Outputs joint position, speed, torque, temperature, voltage, current, and IMU data for advanced robot control.
Optimized for Unitree H2
Designed specifically for the Unitree H2 humanoid robot as a replacement or repair hand.
Technical Specifications
| Feature | Specification |
|---|---|
| Product Model | H2 Dex5-1 FiveFinger Dexterity Hand |
| Compatible Robot | Unitree H2 |
| Active Degrees of Freedom | 16 |
| Finger Configuration | Thumb ×4, Index ×3, Middle ×3, Ring ×3, Little ×3 |
| Transmission Mechanism | 12 Micro-Force-Controlled Composite Transmission Joints + 4 Gear Transmission Joints |
| Four-Finger Lateral Swing | ±22° |
| Minimum Grasping Diameter | 10 mm |
| Fingertip Repeatability | ±1 mm |
| Fingertip Force | 10 N |
| Operating Voltage | 24V–60V |
| Static Current | 58V @ 0.2A |
| Maximum Current | 58V @ 3A |
| Communication Interface | USB 2.0 |
| Communication Rate | 1000 Hz |
| Operating Temperature | -20°C to 60°C |
| Maximum Load Capacity | 3.5 kg (Palm Down, Gripping a 5 cm Round Hard Object) |
| Sensor Feedback | Joint Mode, Position, Speed, Torque, Temperature, Voltage, Current, IMU Data |
| Package | Single Dexterous Hand |
FAQs
Is this hand compatible with other Unitree robots?
No. It is designed specifically for the Unitree H2 humanoid robot.
How many degrees of freedom does the hand provide?
It features 16 active degrees of freedom for precise finger movement.
Does the hand support real-time feedback?
Yes. It provides joint position, speed, torque, temperature, voltage, current, and IMU feedback.
What is the maximum fingertip force?
Each fingertip can generate up to 10N of force.
Is this sold as a pair?
No. The product includes one dexterous hand. Two hands are typically required for a complete H2 robot.
Can this product be purchased as a standalone upgrade?
No. It is supplied as a replacement or repair component for the Unitree H2.
Reviews
There are no reviews yet.