
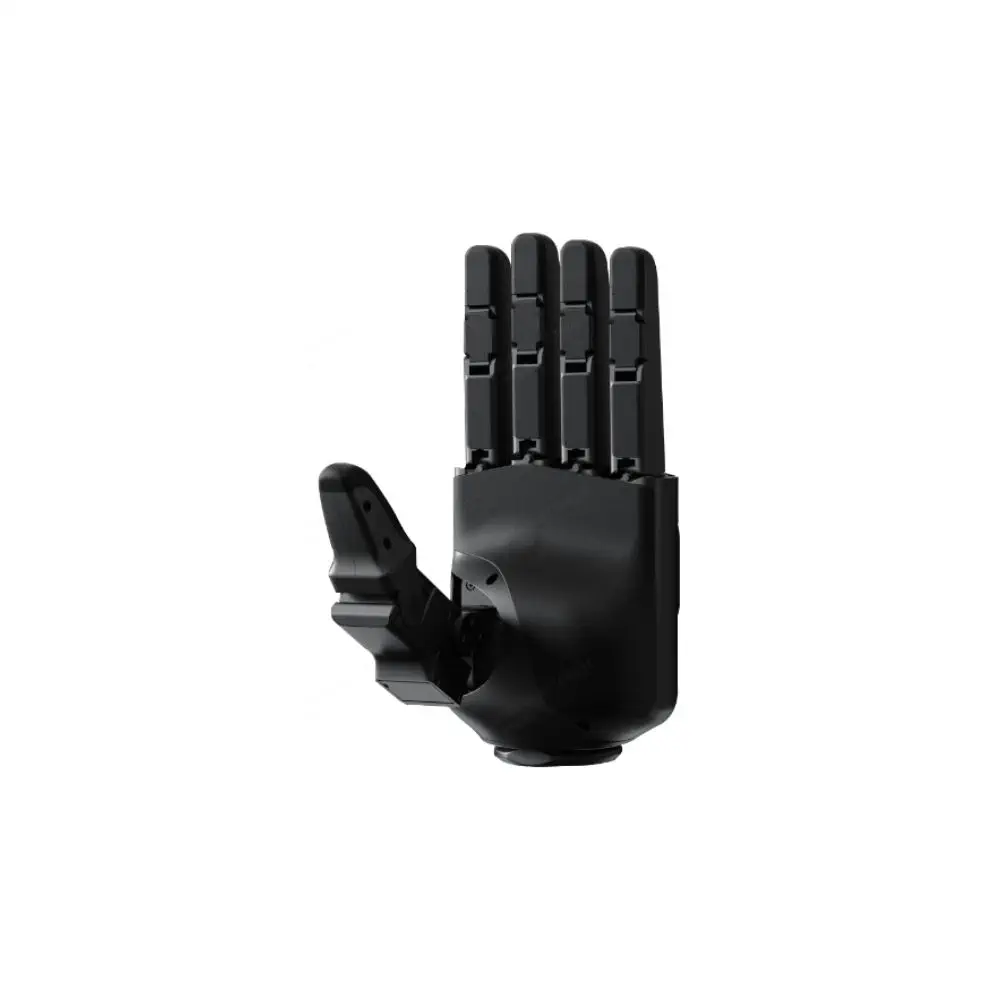
H2 Dex5-1P FiveFinger Dexterity Hand with Tactile Sensing
H2 Dex5-1P FiveFinger Dexterity Hand is an advanced robotic hand developed for the Unitree H2 humanoid robot. Based on the Dex5-1 platform, it combines the same mechanical design with an integrated tactile sensing system that enables more accurate force detection and object interaction.
The hand features 12 tactile sensor arrays containing a total of 94 pressure sensors, allowing it to detect contact forces ranging from 10 g to 2500 g. This makes it suitable for precision grasping, robotic manipulation, AI research, and human-robot interaction where touch feedback is important.
In addition to tactile sensing, the hand provides comprehensive real-time feedback including joint position, joint speed, joint torque, joint temperature, voltage, current, pressure values, sensor temperature, and IMU data. These data streams support advanced robot control, manipulation research, and secondary software development.
This product includes one dexterous hand. A complete Unitree H2 robot typically requires two hands, and customers must specify left or right when ordering. It is intended as a replacement or repair component and cannot be purchased as a standalone upgrade.
Key Features
Integrated Tactile Sensing
Features 94 pressure sensors across 12 sensor arrays for accurate touch and force detection.
Dex5-1 Mechanical Platform
Includes all configurations and functions of the standard Dex5-1 dexterous hand.
Wide Force Detection Range
Detects contact forces from 10 g to 2500 g while supporting a maximum load capacity of 20 kg without sensor damage.
Comprehensive Sensor Feedback
Provides tactile data together with joint position, speed, torque, temperature, voltage, current, and IMU information.
Optimized for Unitree H2
Designed specifically as a replacement or repair hand for the Unitree H2 humanoid robot.
Technical Specifications
| Feature | Specification |
|---|---|
| Product Model | H2 Dex5-1P FiveFinger Dexterity Hand |
| Compatible Robot | Unitree H2 |
| Base Platform | Dex5-1 |
| Tactile Sensor Arrays | 12 |
| Total Pressure Sensors | 94 |
| Array Resolution | Palm: 2 × 5; Finger Pad: 2 × 3 × 5; Finger Tip: 2 × 3 × 5; Finger Base: 2 × 3 × 4 |
| Sensing Range | 10 g–2500 g |
| Maximum Sensor Load | 20 kg (Without Damage) |
| Sensor Feedback | Joint Mode, Joint Position, Joint Speed, Joint Torque, Joint Temperature, Voltage, Current, Pressure Values, Sensor Temperature, IMU Data |
| Package | Single Dexterous Hand (Left or Right) |
FAQs
What is the difference between the Dex5-1P and Dex5-1?
The Dex5-1P includes all Dex5-1 functions while adding 94 integrated pressure sensors for tactile sensing.
How many pressure sensors are built into the hand?
The hand includes 94 pressure sensors arranged across 12 tactile sensor arrays.
What force range can the tactile sensors detect?
The sensing system detects forces from 10 g to 2500 g.
Is this supplied as a pair?
No. The product includes one dexterous hand. A complete Unitree H2 typically requires two hands.
Do I need to specify the left or right hand?
Yes. You must specify whether you require the left-hand or right-hand version when ordering.
Can this hand be purchased separately for upgrades?
No. It is intended as a replacement or repair component and must be ordered with the H2 robot or as an official spare part.
Reviews
There are no reviews yet.