
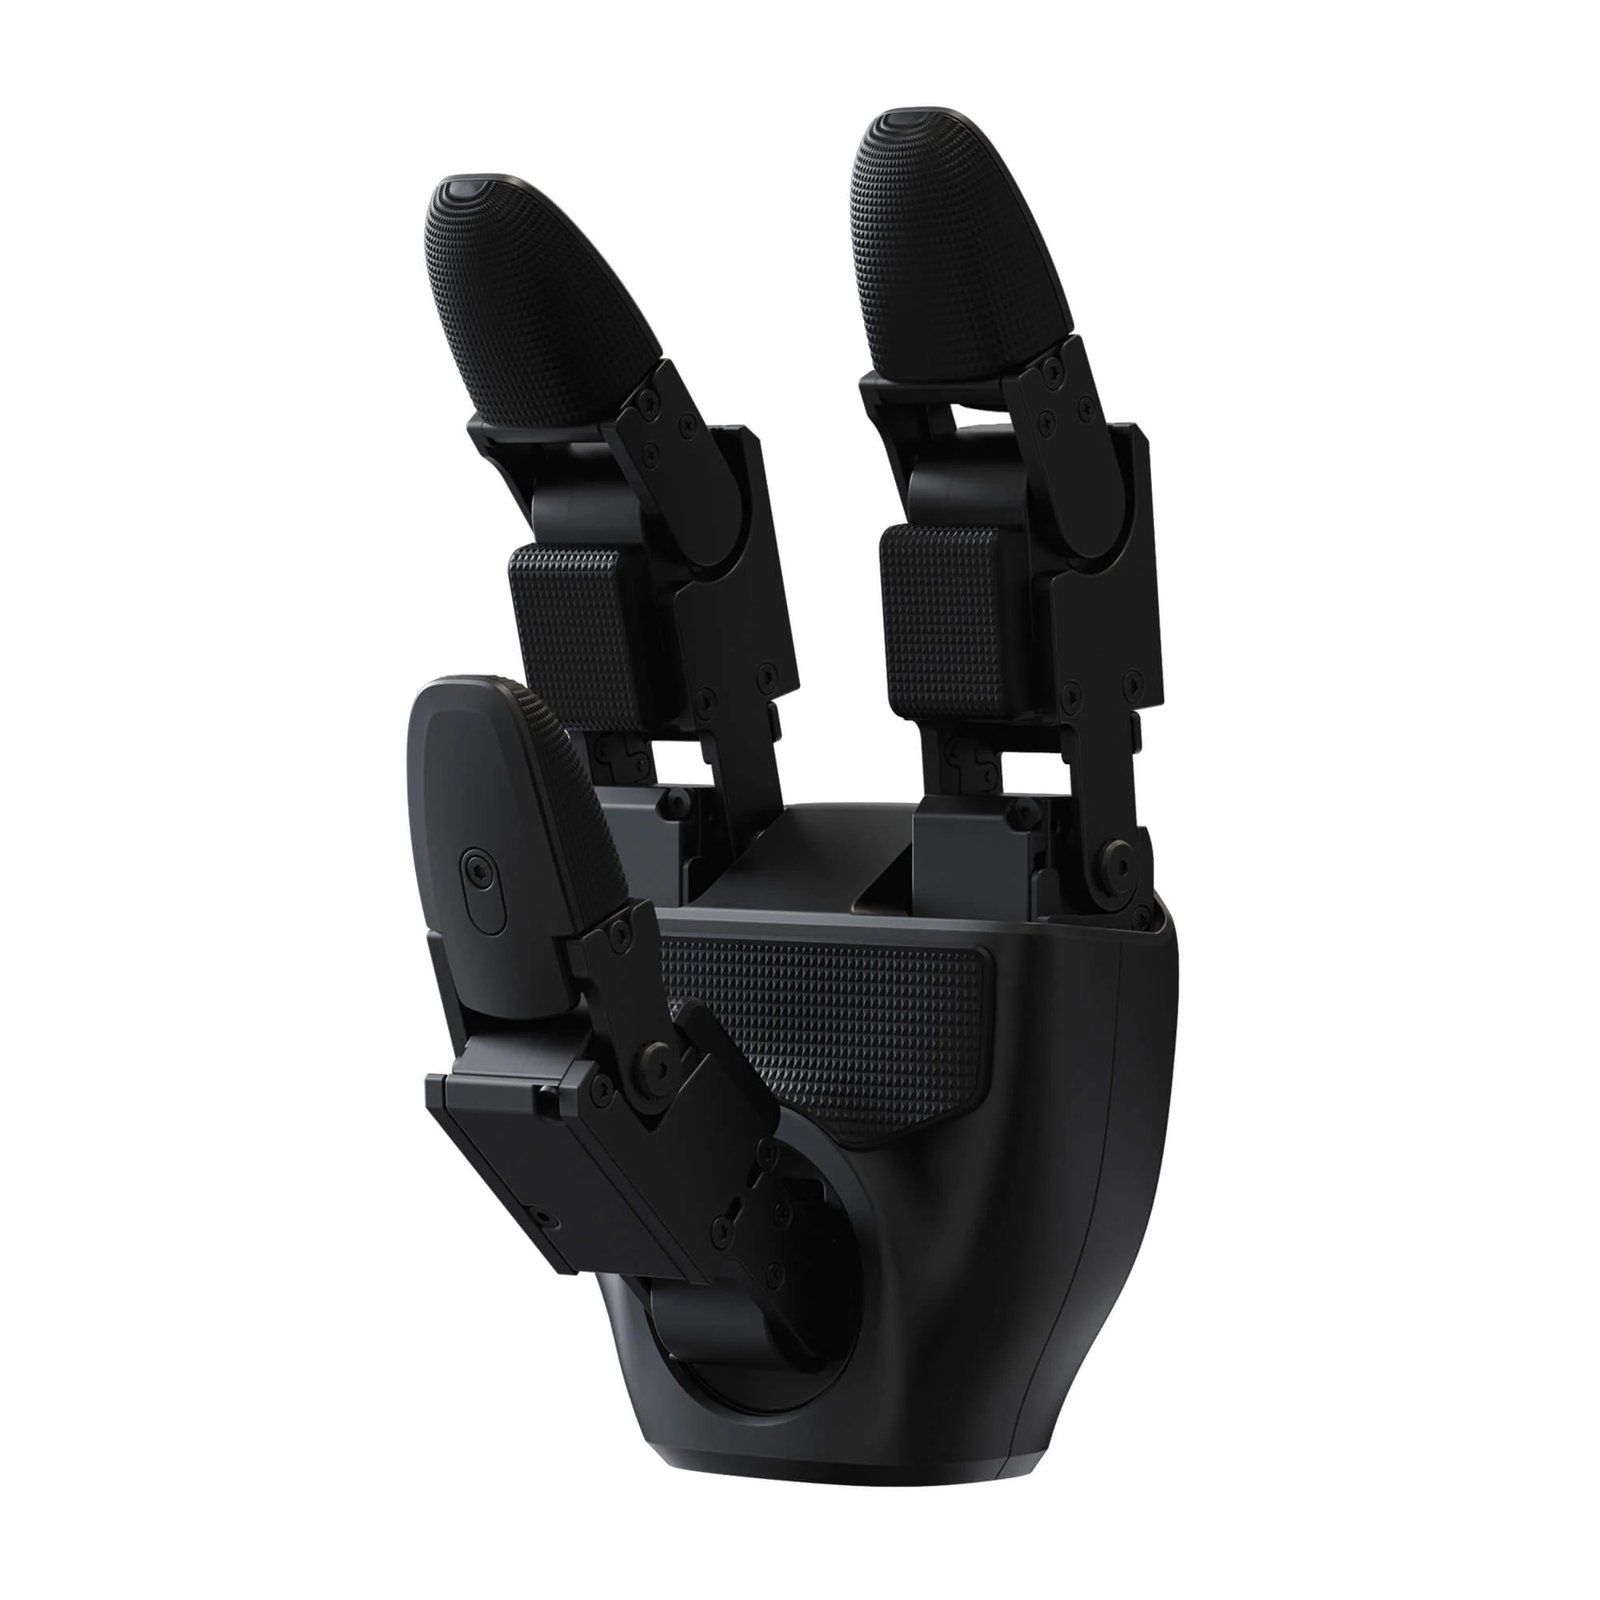
Dex3-1 ForceControlled ThreeFinger Dexterous Hand (Tactile Version)
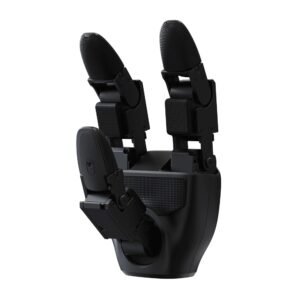
Dex3-1 ForceControlled ThreeFinger Dexterous Hand (Tactile Version) is an advanced robotic hand designed for the Unitree R1 humanoid robot. It combines precise force-controlled finger movement with tactile sensing, making it suitable for AI research, robotic manipulation, and human-robot interaction.
The hand provides 7 degrees of freedom, including 3 degrees of freedom for the thumb, 2 for the index finger, and 2 for the middle finger. This configuration enables stable grasping, pinching, and object handling across a wide range of robotics applications.
Integrated 33 tactile sensors allow the hand to detect contact during manipulation, improving control accuracy and enabling more responsive interaction with objects. With a lightweight design of 650 g, it maintains excellent performance without significantly increasing payload.
Each package includes one left-hand or right-hand unit. A complete Unitree R1 robot typically uses two dexterous hands, and the required side should be specified when ordering.
Key Features
Three-Finger Dexterity
Provides smooth robotic manipulation through a force-controlled three-finger design.
Seven Degrees of Freedom
Supports flexible thumb, index, and middle finger movement for precise grasping.
Integrated Tactile Sensing
Features 33 tactile sensors to improve contact detection and manipulation accuracy.
Lightweight Construction
Compact 650 g design helps maintain robot mobility and balance.
Designed for Unitree R1
Engineered specifically for the Unitree R1 humanoid robot platform.
Technical Specifications
| Feature | Specification |
|---|---|
| Product Model | Dex3-1 ForceControlled ThreeFinger Dexterous Hand (Tactile Version) |
| Compatible Robot | Unitree R1 |
| Product Type | Three-Finger Dexterous Hand |
| Weight | 650 g |
| Dimensions | 175 × 88 × 77 mm |
| Total Degrees of Freedom | 7 |
| Thumb Degrees of Freedom | 3 |
| Index Finger Degrees of Freedom | 2 |
| Middle Finger Degrees of Freedom | 2 |
| Total Tactile Sensors | 33 |
| Hand Configuration | Three-Finger Force-Controlled with Tactile Sensors |
| Package | Single Dexterous Hand (Left or Right) |
FAQs
Which robot is this hand compatible with?
It is designed for the Unitree R1 humanoid robot.
How many tactile sensors are included?
The hand features 33 integrated tactile sensors.
How many degrees of freedom does the hand have?
It provides 7 degrees of freedom.
How much does the hand weigh?
The hand weighs 650 g.
Is it available in left and right versions?
Yes. It is available as left-hand and right-hand models.
How many hands are included?
Each package contains one dexterous hand.
Reviews
There are no reviews yet.